Unitree G1 EDU | U1-U14 | Nền tảng phát triển robot hình người

Các phiên bản: EDU-U4 | Ultimate B
Nền tảng phát triển Unitree G1
Các nền tảng phát triển Unitree G1 Edu cùng các phiên bản Professional và Ultimate là những hệ thống robot hình người dành cho nghiên cứu, phát triển và robot ứng dụng chuyên biệt. Phát triển thứ cấp ở cấp cao và cấp thấp, SDK, thuật toán AI và dock mở rộng 100 TOPS cho phép tạo ra các ứng dụng riêng. Tùy theo mẫu cơ sở, có 23 hoặc 29 bậc tự do. Các phiên bản Professional và Ultimate bổ sung cho nền tảng những giải pháp tay kẹp và bàn tay được cấu hình sẵn, một số có cảm biến xúc giác và camera RGB gắn ở cổ tay. Nhờ đó, đặc biệt có thể phát triển và thử nghiệm các ứng dụng gắp, thao tác và AI.
Điểm nổi bật
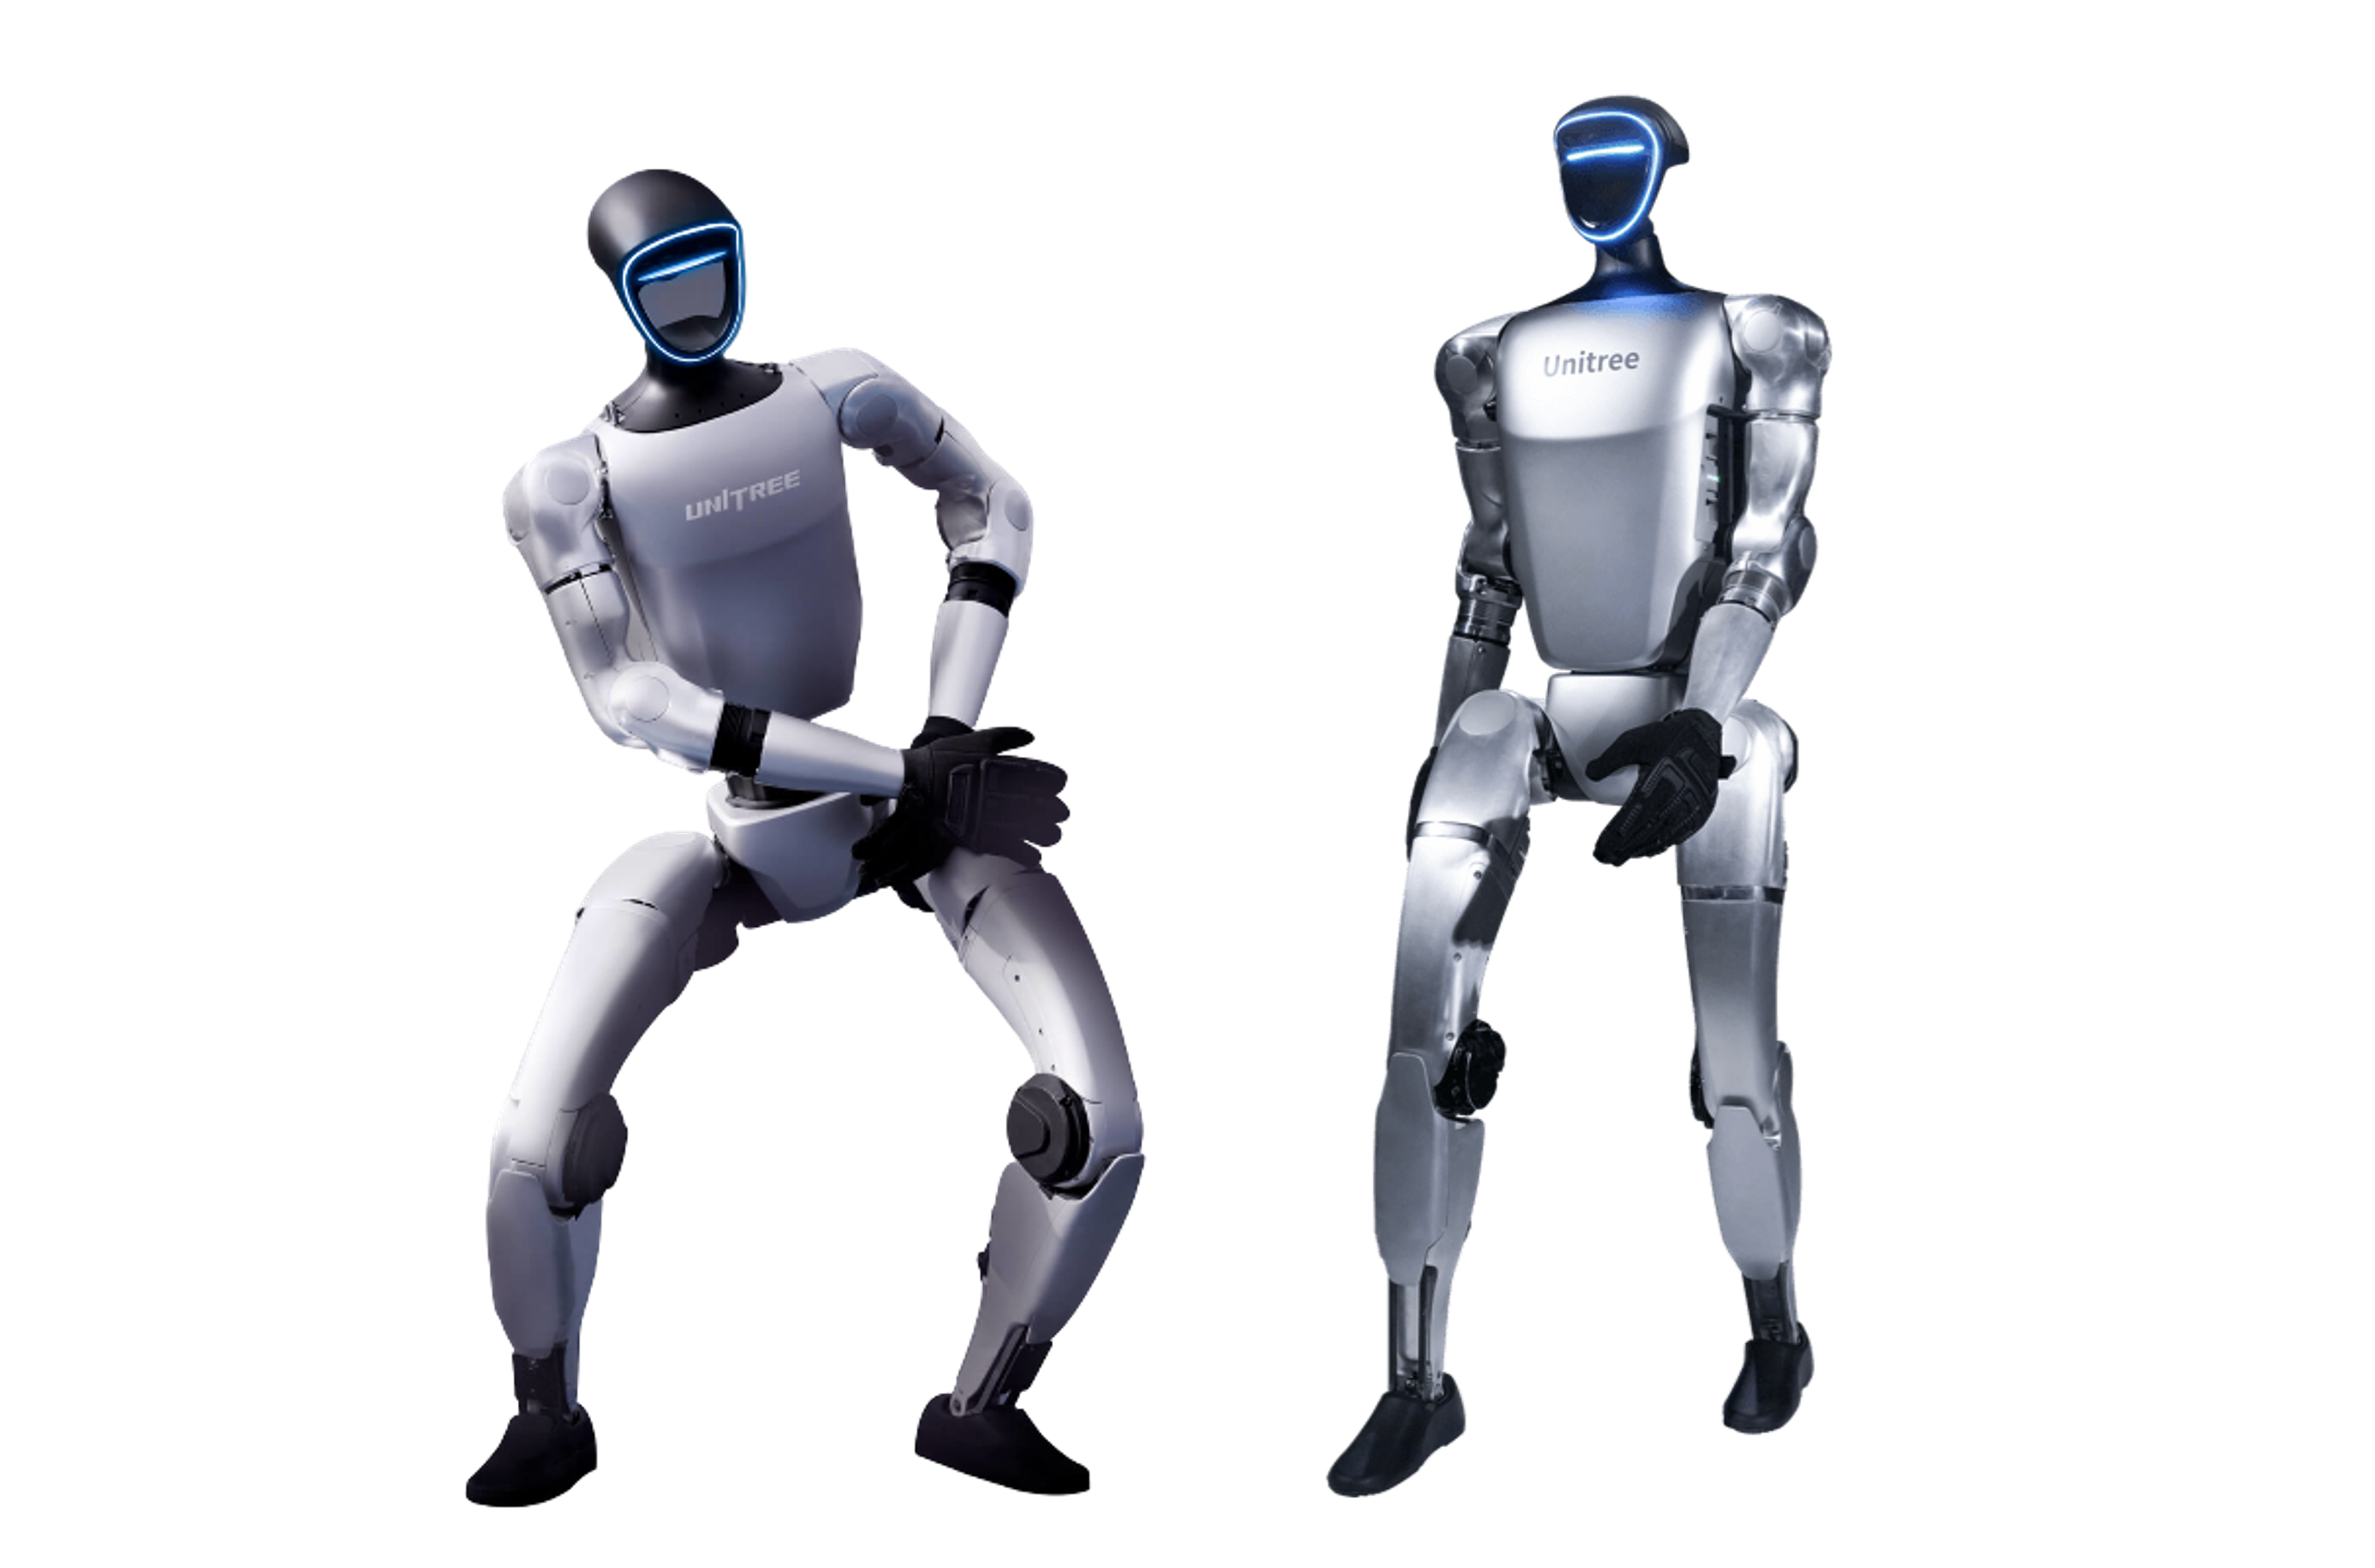
The differences between the development platforms
G1 EDU Standard | 23 DOF | basis of the Professional variants --> Dummy Hand | EDU-U1
G1 EDU Plus | 29 DOF | basis for Ultimate variants --> Dummy Hand | EDU-U2
G1 EDU- Professional (23 DOF Basis)
Professional A → Dex3-1 | 3 Finger | EDU-U9
Professional B → Dex3-1 | 3 Finger with tactile sensors | EDU-U10
Professional E → BrainCo Revo 2 Basic | 5 Finger | EDU-11
Professional F → BrainCo Revo 2 Touch | 5 Finger with tactile sensors | EDU-12
Professional G → Dex2/5 | 5 Finger | EDU-14
Professional H → Dex1-1 Gripper Plus
Professional I → Wuji Hand 2 | 5 Finger
G1 EDU- Ultimate (29 DOF Basis)
Ultimate A → Dex3-1 | 3 Finger | EDU-U3
Ultimate B → Dex3-1 | 3 Finger with tactile sensors | EDU-U4
Ultimate C → Inspire DFQ | 5 Finger | EDU-U5
Ultimate D → Inspire E2 | 5 Finger | with tactile sensors | EDU-U6
Ultimate E → BrainCo Revo 2 Basic | 5 Finger | EDU-U7
Ultimate F → BrainCo Revo 2 Touch | 5 Finger with tactile sensors | EDU-U8
Ultimate G → Dex2/5 | 5 Finger | EDU-13
Ultimate H → Dex1-1 Gripper Plus
Ultimate I → Wuji Hand 2 | 5 Finger
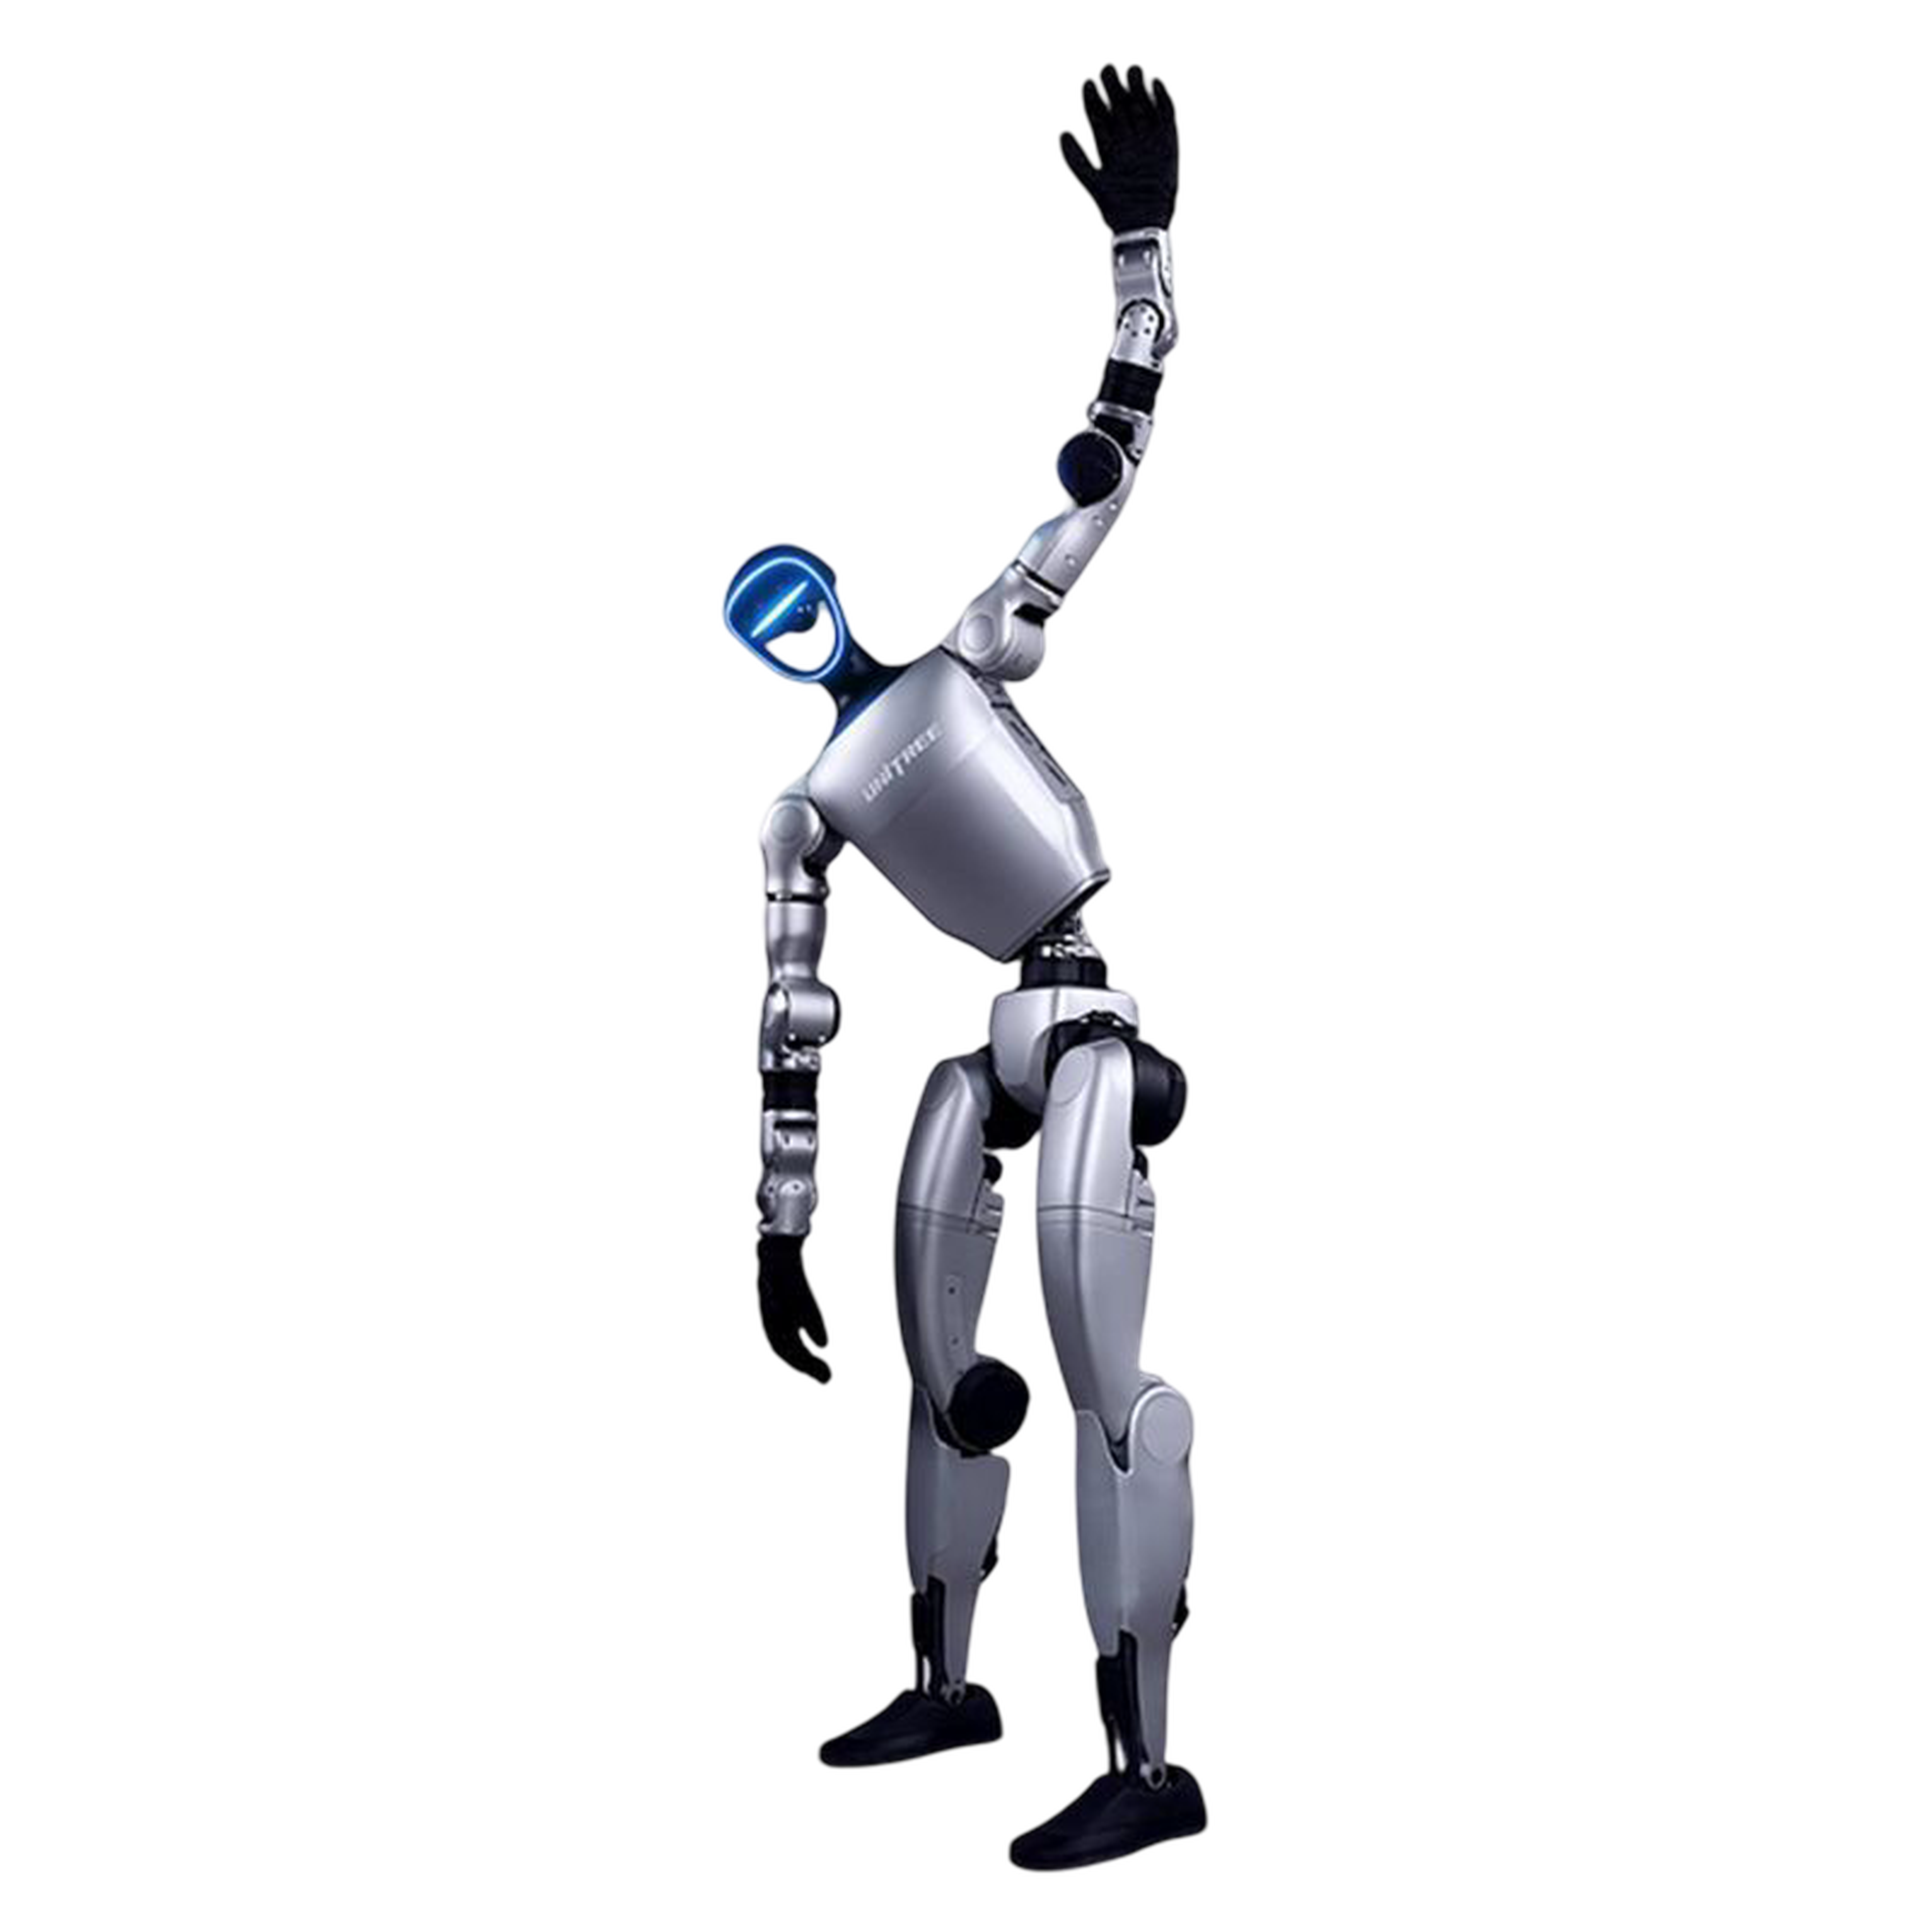
High-Performance Development Platform Unitree G1 EDU U4
The Unitree G1 EDU U4 is a 1,270 mm tall humanoid development platform for research, education, and advanced robotics projects. Weighing around 35 kg, the robot is suitable for laboratory and demonstration setups. The replaceable 13S smart battery provides approximately two hours of operation, depending on motion and computing load. A depth camera and 3D LiDAR provide environmental data for perception, navigation, and autonomous experiments. Dual encoders at the joints, internal cable routing, and local air cooling support repeatable motion. Knee joints with up to 120 Nm of torque and an arm payload of up to 3 kg provide the foundation for dynamic motion sequences, grasping experiments, and mobile manipulation. Payload and motion profiles must be adapted to the specific experimental setup.
Tactile Dex3-1 Three-Finger Hands on the Unitree G1 EDU U4
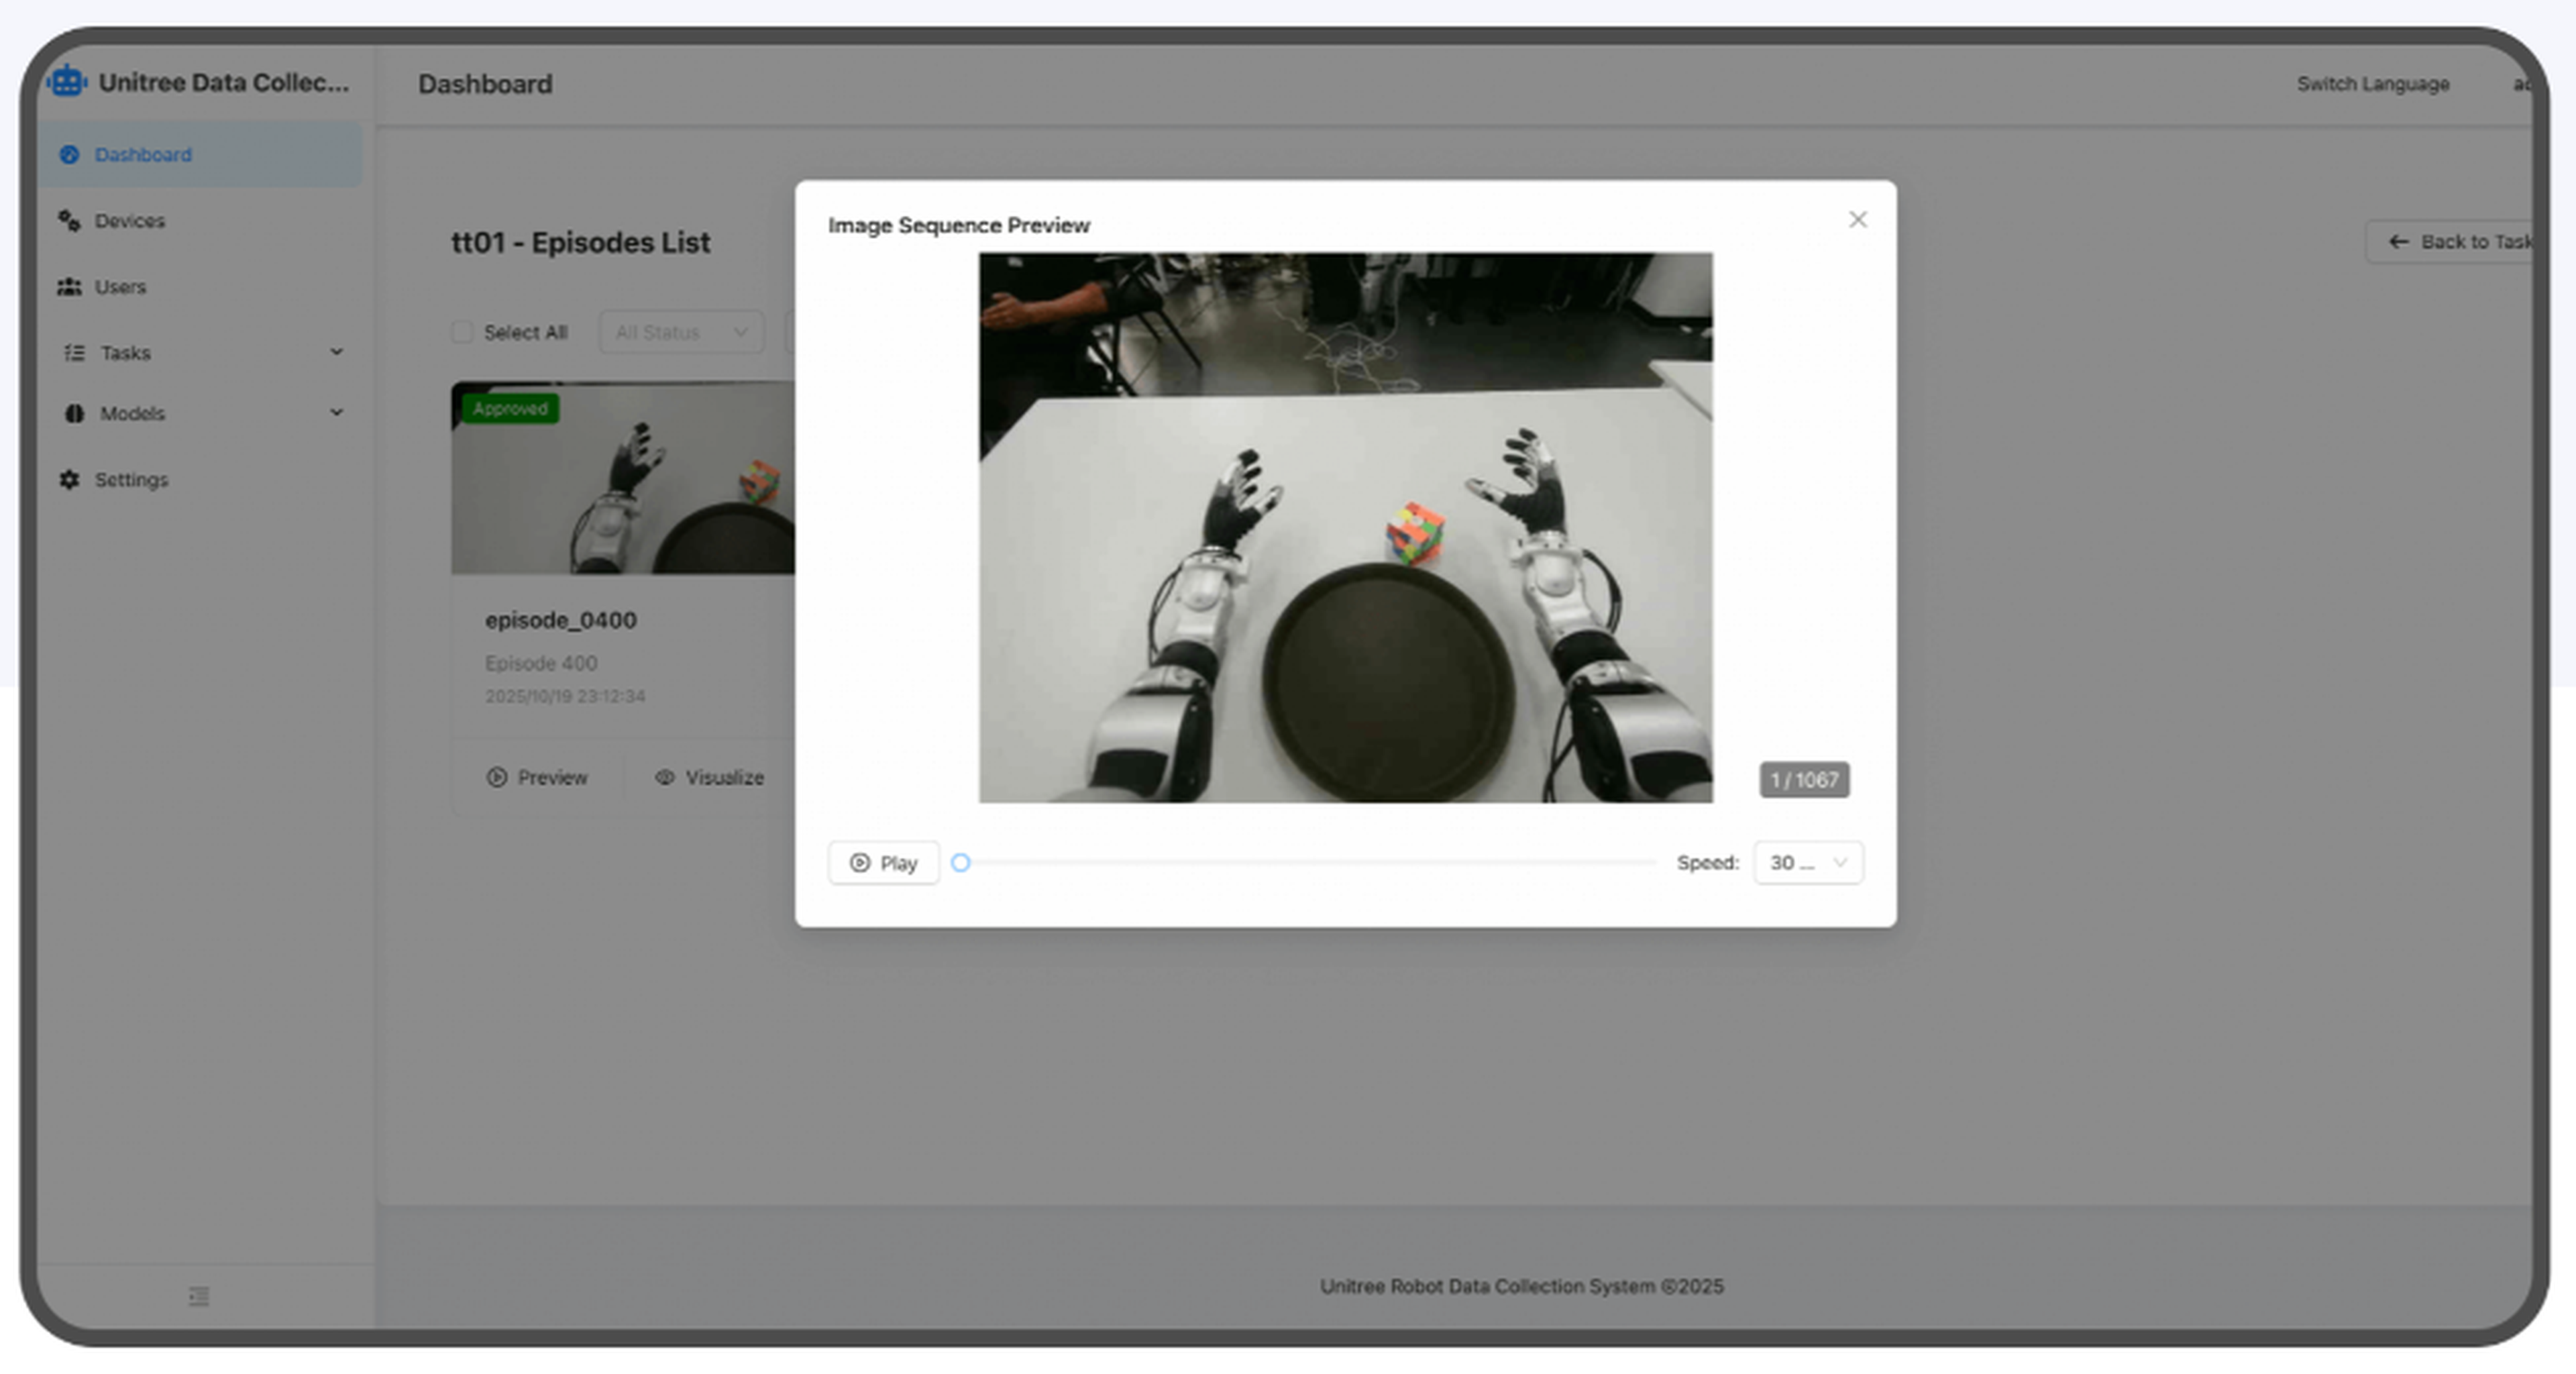
The G1 EDU U4 is configured with force-controlled Dex3-1 three-finger hands featuring tactile sensing. Each hand has seven degrees of freedom: three in the thumb and two each in the index and middle fingers. In addition, 33 tactile sensors per hand capture contact information during grasping and holding. This supports experiments in which not only predefined finger positions but also contact with the object needs to be considered. Each hand weighs approximately 650 g and connects via USB. Wrist-mounted RGB cameras with 1,920 × 1,080 pixels complement the tactile sensing with image data captured close to the working area. This enables object detection, grasp point detection, and contact-based control approaches to be combined within a single experimental setu
Control and Programming the G1 EDU U4
The G1 EDU platform provides high-level and low-level interfaces for custom applications. Developers can use these interfaces to implement motion sequences, joint-level control tasks, and manipulation processes. The integrated expansion dock with up to 100 TOPS is suitable for AI algorithms, machine vision, navigation, and positioning. Wi-Fi 6 and Bluetooth 5.2 facilitate integration into laboratory environments, while Smart OTA supports system updates. When programming the Dex3-1 hands, camera images, finger positions, and tactile contact data can be processed together. This enables the development of grasping strategies that respond to object position and contact. Control cycles, force limits, and abort conditions must be defined for the specific project and tested before operation.
Secondary Development and Model Differences
The G1 EDU U4 combines humanoid locomotion, visual perception, and tactile grasping on a single development platform. Typical areas of focus include balance control, object localization, teleoperation, and mobile manipulation. The three-finger hands enable force-controlled grasping experiments, while tactile sensors detect contact and wrist cameras monitor the working area. Compared with the U3, the U4 adds 33 tactile sensors per hand to the Dex3-1 hand configuration. This makes it suitable for projects that combine visual and contact data for grasp control. Other G1 EDU models use five-finger hands, tendon-driven hands, or parallel grippers. A risk assessment, safety concept, and application-specific integration are required before operation.
Training and Integration provided by RBTX
RBTX supports users with commissioning and integrating the Unitree G1 EDU U4 into a research or demonstration setup. This includes training for operation, programming, and safe testing procedures, as well as selecting additional sensors, computing hardware, and safety components. For applications using the tactile Dex3-1 hands, RBTX can coordinate grasping objects, motion ranges, contact limits, camera positions, and software interfaces. The robot, hand control, machine vision, tactile signals, network, and application are considered as a complete system. This allows the required functionality and acceptance criteria to be defined at an early stage. Force limits, collision zones, the emergency stop concept, and safe retreat motions are taken into account during the concept phase.
Thiết lập giải pháp chi phí thấp với RBTX®
Đặt cuộc gọi video miễn phí với các chuyên gia của chúng tôi